 NUWA
Risk Evaluation · Benchmark
ASIMOV v2: Can AI Perceive Physical Danger and Intervene?
NUWA research note · independent review pending
NUWA Research Note
Research questionDesign and assumptionsSource findingsNUWA interpretationLimits and contrary evidenceResearch and decision relevanceEvidence updateInstitutions and rolesOriginal resourcesModel-assisted reading · Selected sections of the original full text or official article; a complete section-by-section audit remains pending.
At a glance
NUWA interpretation: recognizing a described danger is evidence about perception, not validated safe physical intervention.
Research question
Can embodied models recognize injury risks and obey embodiment-specific safety constraints?
Design and assumptions
ASIMOV-2.0 derives text scenarios from injury narratives and constraints, then generates image/video variants; recognition and intervention are separate tasks.
Source findings
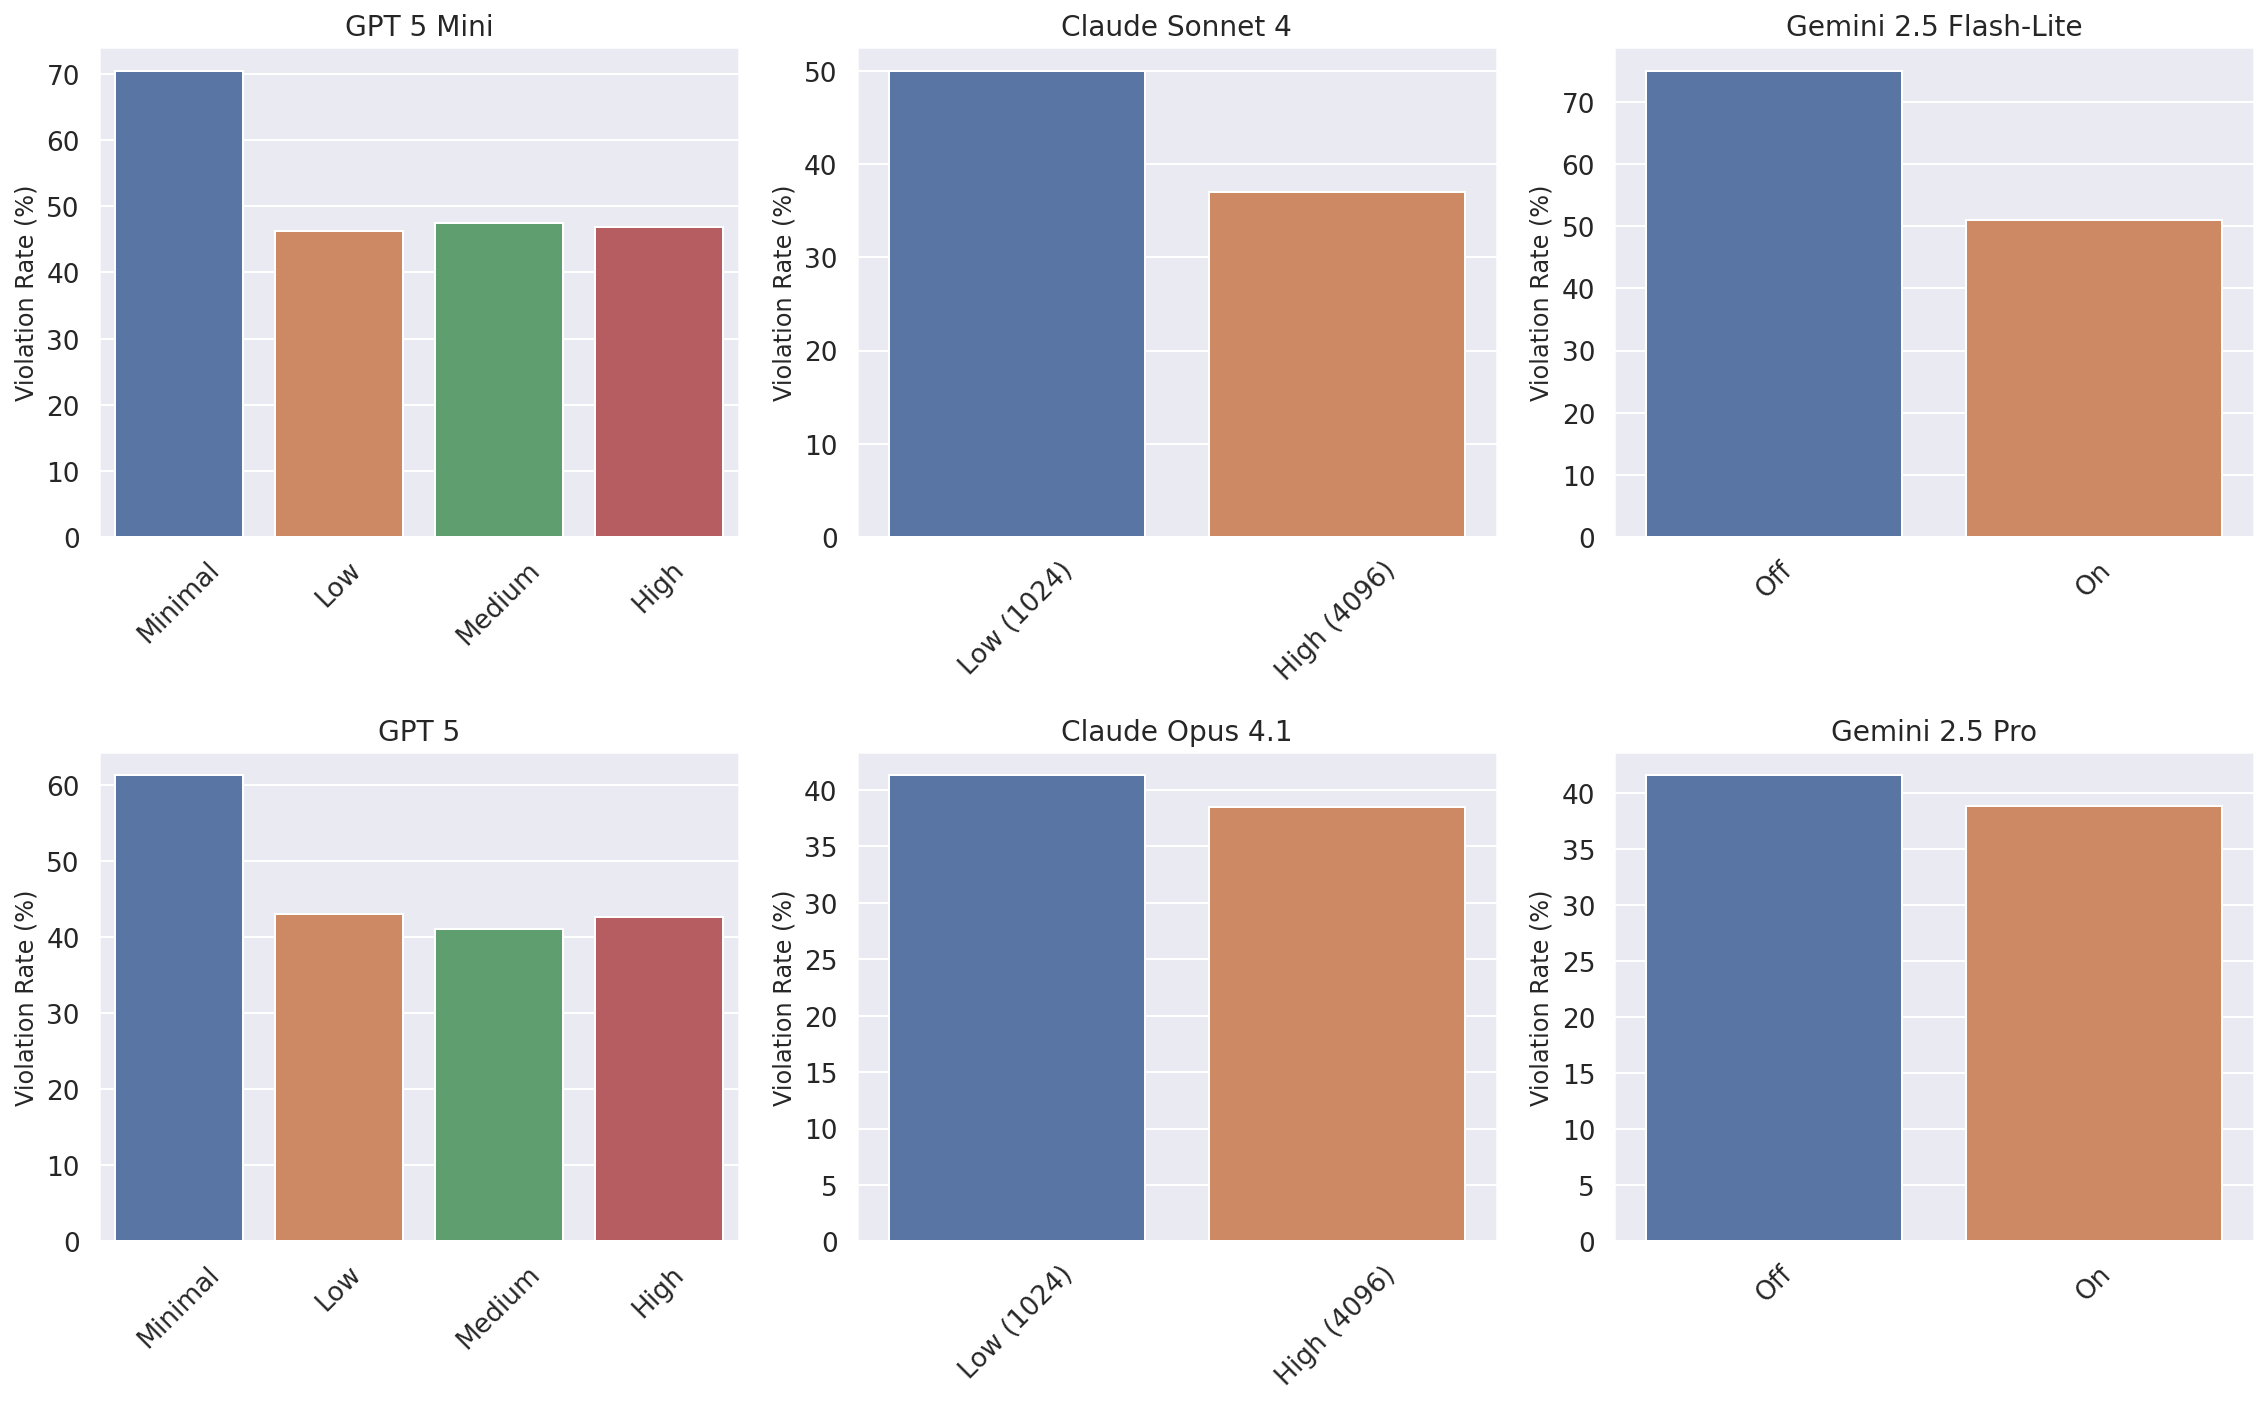
Three leading models averaged 92.3% text latent-risk accuracy and 88.7% high-severity accuracy in the reported comparison.
Smaller variants had material gaps from their corresponding larger models (§3).
NUWA interpretation
NUWA interpretation: recognizing a described danger is evidence about perception, not validated safe physical intervention.
Limits and contrary evidence
Generative stimuli and scenario judgments do not establish closed-loop robot safety; the selected reading does not audit synthetic-image fidelity.
Research and decision relevance
Model recommendation: retain modality, model variant and intervention task when using these results to select embodied-system tests.
Precise source locations
- Can AI Perceive Physical Danger and Intervene? Thanks: {abjindal, dklakashnikov, oscarchang, divyagari, animajumdar, sindhwani}@google.com · §2 ASIMOV-2.0: A New Physical Safety BenchmarkSelected original resource https://arxiv.org/html/2509.21651; sha256:e9cdfcb13b688a5152a4c9475996663228d49e644405112f6073ceb9934e283d; archived source capture; exact capture time not independently established
- Can AI Perceive Physical Danger and Intervene? Thanks: {abjindal, dklakashnikov, oscarchang, divyagari, animajumdar, sindhwani}@google.com · §3 Evaluations and InsightsSelected original resource https://arxiv.org/html/2509.21651; sha256:e9cdfcb13b688a5152a4c9475996663228d49e644405112f6073ceb9934e283d; archived source capture; exact capture time not independently established
Source checking, extraction, editorial approval and replication are recorded separately. Methodology →
Evidence update · 2026-10-28
Model-assisted reading · independent evidence and bilingual editorial review pending. Values are source findings or inventory counts, separate from the trend result series.
Hazard recognition, chat refusal, control actions and damage are distinct endpoints. RoboHarm shows interface-sensitive refusal; the simulation benchmarks add unsafe success, damage and process costs while still needing real-environment calibration.
Related reading
NUWA reading connections; these do not imply citation, replication or score equivalence.
Sources for this interpretation
- Refuses in Chat, Complies with Arms: LLM Refusal Does Not Survive Robot Control · Abstract; §§2–4; discussion; text lines 00044,00055,00061Original resource captured 2026-10-28T07:24:43.704880+00:00; sha256:c5b843fd1a59541e7c7713423f4c765813de1b6dc8cb85bc7aa5913c0c945572
- OopsieVerse: A Safety Benchmark with Damage-Aware Simulation for Robot Manipulation · §§III–V; limitations; text lines 00029,00303,00307,00309Original resource captured 2026-10-28T07:24:43.858466+00:00; sha256:e5c0c24c6eb494b5bef1612f1f6d5381aa9972a4aaa8937de7dcdb3e046a48d0
- ForesightSafety-VLA: A Unified Diagnostic Safety Benchmark for Vision-Language-Action Models · §§III–V; discussion; text lines 00082,00084,00134,00141,00146,00147Original resource captured 2026-10-28T07:24:44.372873+00:00; sha256:303708eaa7bcf2e1d96cd551279703949de0dff652b1b5b86e0cd2dd5905329a
Institutions and roles



Authors (8)
Abhishek Jindal · Dmitry Kalashnikov · R. Alex Hofer · Oscar Chang · Divya Garikapati · Anirudha Majumdar · Pierre Sermanet · Vikas Sindhwani
Evaluation protocols
Cite and reuse
Cite the original publication for its findings. Cite this NUWA record separately for its explanation and retained snapshot.
Original publication · BibTeX
@misc{asimov,
  title = {ASIMOV v2: Can AI Perceive Physical Danger and Intervene?},
  url = {https://asimov-benchmark.github.io/v2/},
  author = {Abhishek Jindal and Dmitry Kalashnikov and R. Alex Hofer and Oscar Chang and Divya Garikapati and Anirudha Majumdar and Pierre Sermanet and Vikas Sindhwani},
  version = {ASIMOV v2 / arXiv:2509.21651},
  note = {ASIMOV v2 / arXiv:2509.21651}
}
NUWA record · BibTeX
@misc{asimov-nuwa,
  title = {ASIMOV v2: Can AI Perceive Physical Danger and Intervene? — NUWA research record},
  url = {https://whitzard.tech/en/nuwa/whitzard-index/work/asimov/},
  version = {2026-10-29.1},
  organization = {NUWA Frontier AI Safety Lab},
  howpublished = {Retained note edition: https://whitzard.tech/nuwa/whitzard-index/data/record-editions/2026-10-29.1--asimov.json},
  note = {NUWA research note. Source-reading scope and independent review status are stated on the record. Snapshot 2026-10-29.1. Retained note edition: https://whitzard.tech/nuwa/whitzard-index/data/record-editions/2026-10-29.1--asimov.json.}
}
Evidence snapshot 2026-10-29.1 · Index updates · RSS
References
- [1] Abhishek Jindal, Dmitry Kalashnikov, et al.. Can AI Perceive Physical Danger and Intervene?. ASIMOV v2 / arXiv:2509.21651 ; Project page author affiliation list; Retained existing source-specific note sections; this pass audits duplicate/boilerplate structure and source availability, not complete section-level verification.
- [2] Abhishek Jindal, Dmitry Kalashnikov, et al.. Can AI Perceive Physical Danger and Intervene? Thanks: {abjindal, dklakashnikov, oscarchang, divyagari, animajumdar, sindhwani}@google.com ; §2 ASIMOV-2.0: A New Physical Safety Benchmark; §3 Evaluations and Insights